
In the intricate dance of engineering and artificial intelligence, the concept of a “motor unit” transcends its original biological definition to become a cornerstone of modern technological innovation. While classically understood as a biological system comprising a single motor neuron and the muscle fibers it innervates, in the realm of technology, a “motor unit” can be analogously defined as a fundamental functional assembly responsible for translating electrical or computational signals into precise physical motion. This technological interpretation is critical for everything from the delicate movements of robotic arms to the sophisticated locomotion of autonomous vehicles, embodying the very essence of controlled action in the digital age.
This article delves into the technological definition of a motor unit, exploring its components, design principles, diverse applications, and the challenges and future directions that are shaping its evolution. By understanding the technological motor unit, we uncover the hidden gears driving the mechanics of our increasingly automated and intelligent world.
From Biological Blueprint to Robotic Actuation: The Technological Motor Unit
The natural world has long served as a profound source of inspiration for engineers, and the biological motor unit is a prime example. Its inherent efficiency, precision, and scalability in controlling movement have provided a compelling blueprint for technological solutions.
Understanding the Biological Inspiration
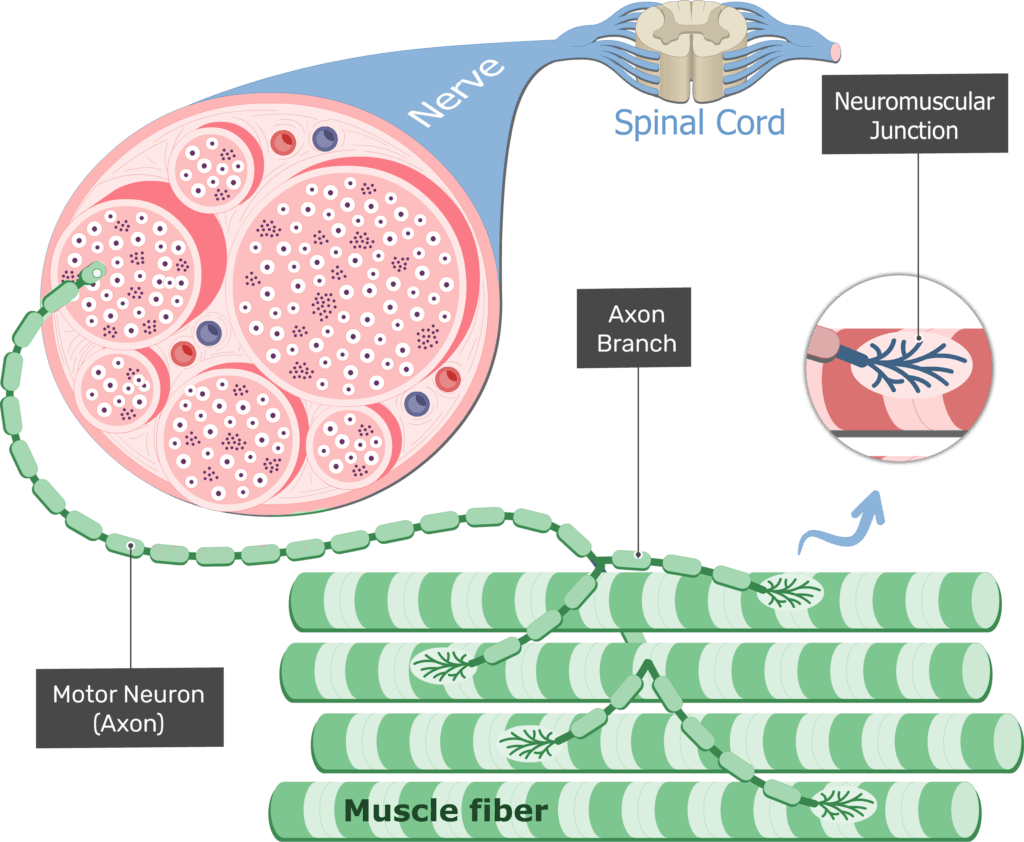
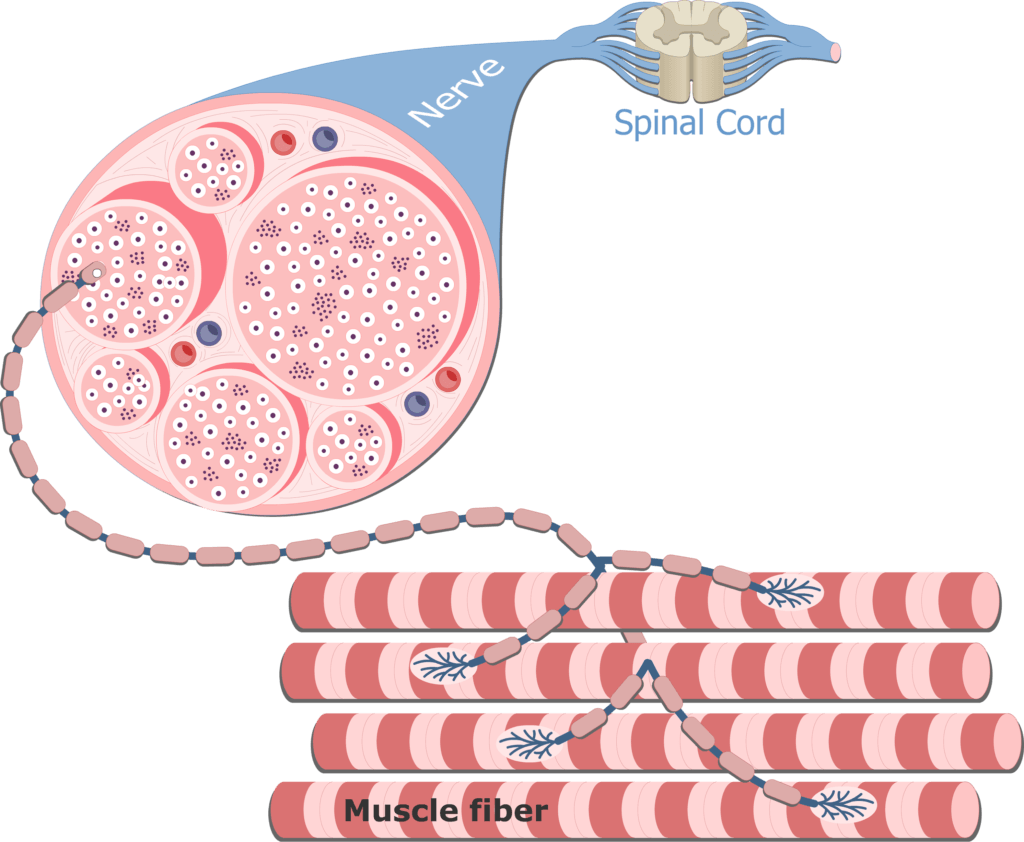
At its biological core, a motor unit is the smallest functional unit of muscle contraction. A motor neuron originating in the spinal cord extends its axon to a muscle, where it branches out to innervate multiple muscle fibers. When this motor neuron fires, all the muscle fibers it innervates contract simultaneously. The brain orchestrates movement by recruiting different numbers and types of motor units, allowing for a wide spectrum of force and precision, from lifting a feather to heavy weightlifting. This elegant system showcases a remarkable integration of sensing, processing, and actuation—a triad that engineers strive to replicate and enhance in artificial systems. The ability to vary force by recruiting more units (spatial summation) or increasing the firing rate of existing units (temporal summation) is a design principle that finds direct parallels in technological control systems.
Defining the Technological Equivalent
In the technological context, a “motor unit” encapsulates the integrated components required to achieve controlled physical movement in a machine. It’s more than just a motor; it’s a complete subsystem that receives commands, converts them into mechanical force, and often incorporates feedback to ensure accuracy. Essentially, a technological motor unit is comprised of three primary conceptual elements:
-
A Controller/Intelligence Module: This is the “brain” of the unit, receiving high-level commands (e.g., “move arm to position X,” “rotate wheel 90 degrees”). It could be a microcontroller, a dedicated driver board, or an embedded AI module.
-
An Actuator: This is the component that generates the physical force or motion. Common actuators include electric motors (DC, servo, stepper), pneumatic cylinders, hydraulic pistons, or even more exotic materials like shape memory alloys.
-
A Feedback Mechanism (Optional but Crucial): Often, this includes sensors (e.g., encoders, potentiometers, accelerometers) that provide real-time information about the actuator’s position, velocity, or force. This feedback is essential for closed-loop control, allowing the controller to make adjustments and ensure the desired movement is achieved accurately.
This integrated approach mirrors the biological motor unit’s function, where a command from the brain (controller) is translated into muscle contraction (actuator), with proprioception providing sensory feedback on the limb’s position.
Key Components of a Robotic Motor Unit
A closer look at the constituent parts of a typical robotic motor unit reveals a sophisticated interplay of electronics and mechanics:
-
Motors: The most common actuators are electric motors.
-
DC Motors: Simple, cost-effective, offer high speed, but require gearing and feedback for precise positioning.
-
Stepper Motors: Excellent for precise, open-loop positioning (moving in discrete steps) but can lose steps under load.
-
Servo Motors: Integrate a DC motor, gearbox, and feedback sensor (encoder or potentiometer) into a single unit, providing precise angular positioning. They are the workhorses of many robotic joints.
-
-
Motor Drivers: Electronic circuits that amplify signals from the microcontroller to provide sufficient current and voltage to power the motor. They often include features like H-bridges for bidirectional control and pulse-width modulation (PWM) for speed control.
-
Sensors: Encoders (rotary or linear) are vital for measuring position and velocity, providing the feedback necessary for closed-loop control. Force sensors, accelerometers, and gyroscopes can also be integrated for more advanced control schemes.
-
Microcontrollers/Processors: The computational hub, running algorithms to interpret commands, process sensor data, and generate control signals for the motor driver. Examples include Arduino, Raspberry Pi, or specialized embedded controllers.
-
Gearing: Often essential for matching motor speed and torque to the requirements of the mechanical load, enhancing the force output, and improving resolution.
Precision and Control: The Core of Advanced Motor Unit Design
The true power of a technological motor unit lies in its ability to execute movements with extraordinary precision and adaptability. This is achieved through sophisticated control mechanisms that often draw parallels to biological neural pathways.
The Importance of Feedback Systems
Just as our brain receives continuous sensory input about our body’s position and movement, technological motor units rely heavily on feedback systems for accurate control. Encoders, for instance, convert rotational or linear motion into electrical signals, allowing the controller to know the exact position of the motor shaft or the mechanical linkage. Without this feedback, achieving precise, repeatable movements is nearly impossible, as motors are susceptible to variations in load, friction, and power supply.
Common control algorithms, such as PID (Proportional-Integral-Derivative) controllers, leverage this feedback. The PID controller continuously calculates an “error” value as the difference between a desired setpoint (target position/velocity) and the measured process variable (actual position/velocity). It then applies a corrective output based on proportional, integral, and derivative terms to minimize this error, ensuring the motor unit reaches and maintains its target state smoothly and accurately, mimicking the brain’s ability to fine-tune muscle contractions.
Microcontroller Integration and Algorithms
The microcontroller acts as the central nervous system for the motor unit. It’s programmed with the logic and algorithms necessary to:
-
Interpret Commands: Receive instructions from a higher-level system (e.g., a robot’s main processor, a user interface).
-
Process Sensor Data: Read and filter data from encoders and other sensors to determine the current state of the actuator.
-
Execute Control Algorithms: Apply PID or other advanced control loops to calculate the necessary motor output.
-
Generate Control Signals: Send PWM signals to the motor driver to regulate speed and direction.
Advanced algorithms can enable adaptive control, allowing the motor unit to adjust its behavior in response to changes in the environment or load, much like our muscles adapt to lifting different weights. This level of intelligence at the individual unit level is crucial for the dexterity and robustness of modern robotic systems.

Modular Design and Scalability
Modern technological motor units are often designed with modularity in mind. This means they are self-contained, interchangeable, and easily integrated into larger, more complex systems. This approach offers several advantages:
-
Ease of Assembly and Maintenance: Units can be quickly swapped out for repair or upgrade.
-
Scalability: Identical or similar units can be combined to create larger, multi-axis robots or systems with many degrees of freedom, from a small drone to a large industrial manipulator.
-
Design Flexibility: Engineers can choose from a library of pre-designed motor units, each optimized for specific torque, speed, or precision requirements, without having to design every component from scratch.
This modularity allows for the creation of intricate robotic architectures, where dozens or even hundreds of motor units work in concert, much like a symphony of biological motor units collaborating to produce complex human movements.
Applications Across the Tech Landscape
The technological motor unit is an unsung hero, silently powering a vast array of innovations that define our modern technological landscape. Its applications span from industrial manufacturing to personal assistance and beyond.
Robotics and Automation
This is arguably the most prominent domain for technological motor units. In industrial robotics, precision servo motor units enable robotic arms to perform repetitive tasks with sub-millimeter accuracy, from welding car chassis to assembling delicate electronics. Humanoid robots utilize an extensive network of motor units in their joints to achieve bipedal locomotion, balance, and dexterous manipulation, striving to mimic human agility and fluidity. Collaborative robots (cobots) rely on highly sensitive and responsive motor units, often equipped with force-torque sensors, to safely interact with human co-workers, detecting contact and adjusting their movements accordingly. The ability of these units to execute precise, repeatable, and adaptable movements is the bedrock of industrial and service automation.
Advanced Prosthetics and Exoskeletons
In the medical and assistive technology fields, motor units are revolutionizing the lives of individuals with disabilities. Advanced prosthetic limbs incorporate miniature, powerful motor units to provide lifelike movement in fingers, wrists, and ankles. These units are often controlled by interpreting bio-signals (e.g., EMG signals from residual muscles, or even direct neural interfaces), allowing users to intuitively command their prosthetic devices. Exoskeletons, designed to augment human strength or assist in rehabilitation, leverage arrays of motor units to provide guided movement, support body weight, or enhance lifting capabilities, demonstrating a direct interplay between human intention and mechanical action.
AI-Driven Systems and Smart Devices
Beyond traditional robotics, motor units are the physical interface for many AI-driven systems and smart devices. Drones rely on brushless DC motor units for propulsion and precise flight control, allowing AI algorithms to navigate complex environments. Smart home devices, such as automated blinds, robotic vacuums, or intelligent door locks, use small, efficient motor units to perform their functions, responding to voice commands or environmental sensors. Even in augmented reality (AR) and virtual reality (VR) haptic feedback devices, tiny motor units called linear resonant actuators (LRAs) or eccentric rotating mass (ERM) motors provide tactile sensations, immersing users further into digital experiences. In essence, whenever AI needs to interact physically with the real world, a motor unit is almost certainly involved.
Challenges and Future Directions in Motor Unit Technology
Despite their widespread utility, technological motor units are continuously evolving. Researchers and engineers face several challenges and are exploring exciting new directions to push the boundaries of what these fundamental components can achieve.
Miniaturization and Energy Efficiency
A persistent challenge is to develop motor units that are simultaneously smaller, lighter, more powerful, and more energy-efficient. Miniaturization is crucial for applications in microrobotics, surgical instruments, and more compact wearable devices. Achieving higher power density without increasing size or weight, while also reducing energy consumption (especially for battery-powered devices), remains a key area of focus. Innovations in motor materials, magnetic circuits, and power electronics are vital to addressing these demands.
Enhanced Haptics and Bio-integration
The next frontier involves making robotic and prosthetic movements not only functional but also more natural and intuitive. This includes improving haptic feedback, allowing users to “feel” what their robotic manipulators or prosthetic limbs are interacting with. Advanced motor units are being developed with integrated force and tactile sensors that can relay rich sensory information back to the user or higher-level control system. Furthermore, efforts are underway to achieve seamless bio-integration, where artificial motor units can directly interface with biological nervous systems, potentially leading to more intuitive and responsive control for advanced prosthetics and neuroprosthetics.
The Role of AI in Adaptive Control
Artificial intelligence, particularly machine learning, is poised to revolutionize motor unit control. Current control systems are often pre-programmed or rely on fixed algorithms. However, AI can enable motor units to learn and adapt autonomously. Machine learning algorithms can analyze vast amounts of sensor data, predict outcomes, and optimize control parameters in real-time, allowing robotic systems to exhibit unprecedented levels of adaptability, robustness, and autonomy in unpredictable environments. This includes learning optimal gaits for legged robots, fine-tuning manipulation strategies, and even self-diagnosing and compensating for wear and tear, truly pushing the boundaries toward self-aware and self-optimizing robotic systems.
Conclusion
The definition of a motor unit, in a technological context, describes a fundamental, integrated assembly designed to translate computational commands into precise physical motion. Far from being a mere collection of parts, it represents a sophisticated blend of mechanical engineering, electronics, and control theory, drawing conceptual inspiration from the biological world to achieve unprecedented levels of dexterity and automation.
From industrial robots that meticulously assemble our goods to advanced prosthetics that restore mobility, and from AI-driven drones that navigate our skies to smart devices that simplify our homes, technological motor units are the silent, powerful engines of innovation. As we continue to push the boundaries of miniaturization, energy efficiency, and AI-driven adaptive control, these pivotal components will continue to evolve, enabling a future where machines move with greater precision, intelligence, and seamless integration into the human experience. The journey from a biological blueprint to sophisticated engineered marvels underscores the enduring power of observation and ingenuity in shaping our technological world.
aViewFromTheCave is a participant in the Amazon Services LLC Associates Program, an affiliate advertising program designed to provide a means for sites to earn advertising fees by advertising and linking to Amazon.com. Amazon, the Amazon logo, AmazonSupply, and the AmazonSupply logo are trademarks of Amazon.com, Inc. or its affiliates. As an Amazon Associate we earn affiliate commissions from qualifying purchases.